Sandro Papais

I’m a Ph.D. Candidate at the University of Toronto Robotics and AI Lab with Prof. Steven Waslander, an Affiliate Researcher at the Vector AI Institute, and a Machine Learning Engineer at Zoox.
I build spatiotemporal transformer models that let robots perceive and act in real time. My current research develops end-to-end foundation models for perception, prediction, and planning for autonomous driving applications. I also co-authored a book on motion prediction for robotics in Foundations and Trends in Robotics.
Previously, I developed autonomy software for interplanetary spacecraft at NASA JPL, lunar landers and eVTOLs at NGC Aerospace (some of which has now flown to the Moon), and planetary rovers at the European Space Agency. I also developed course materials for the Self-Driving Cars Specialization on Coursera, used by 120k+ learners.
Recognition includes the Qualcomm Innovation Fellowship for autonomous driving foundation models research, Ontario Graduate Scholarship for spatiotemporal perception research, AutoDrive Challenge II 1st place, and Spaceport America Genesis Cup 1st place.
Blog Posts
Selected Publications
-
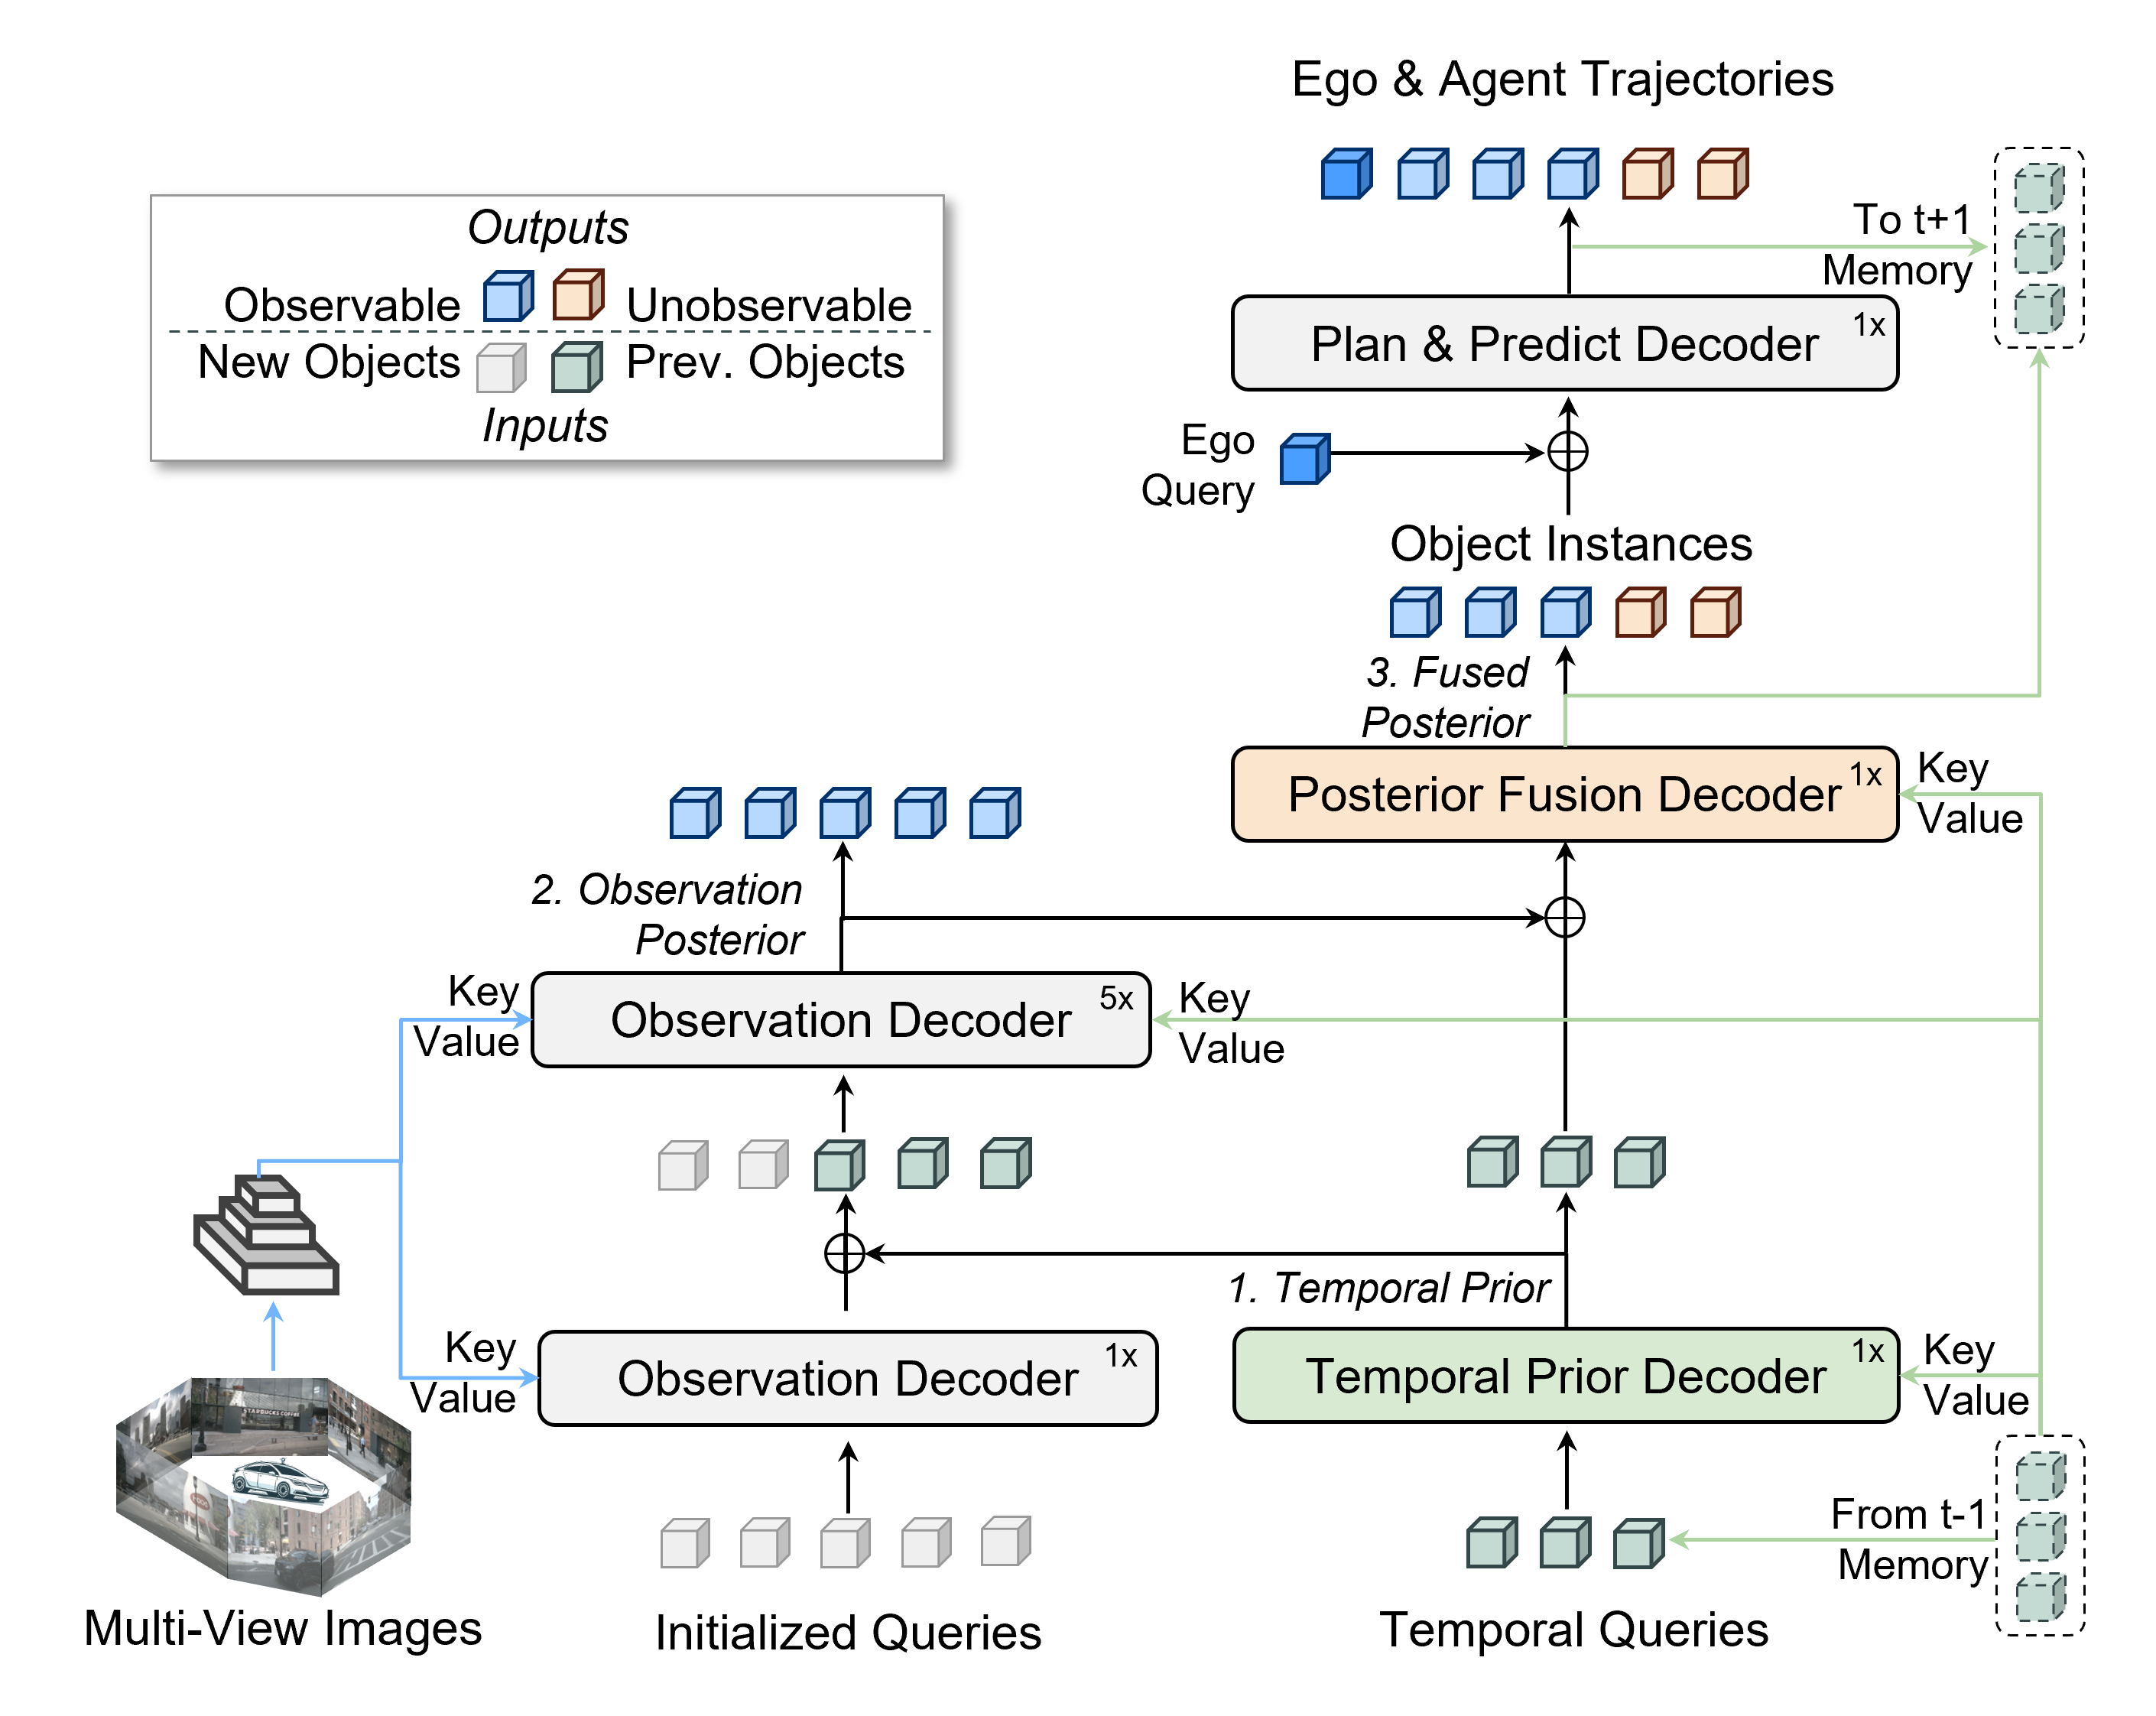
-
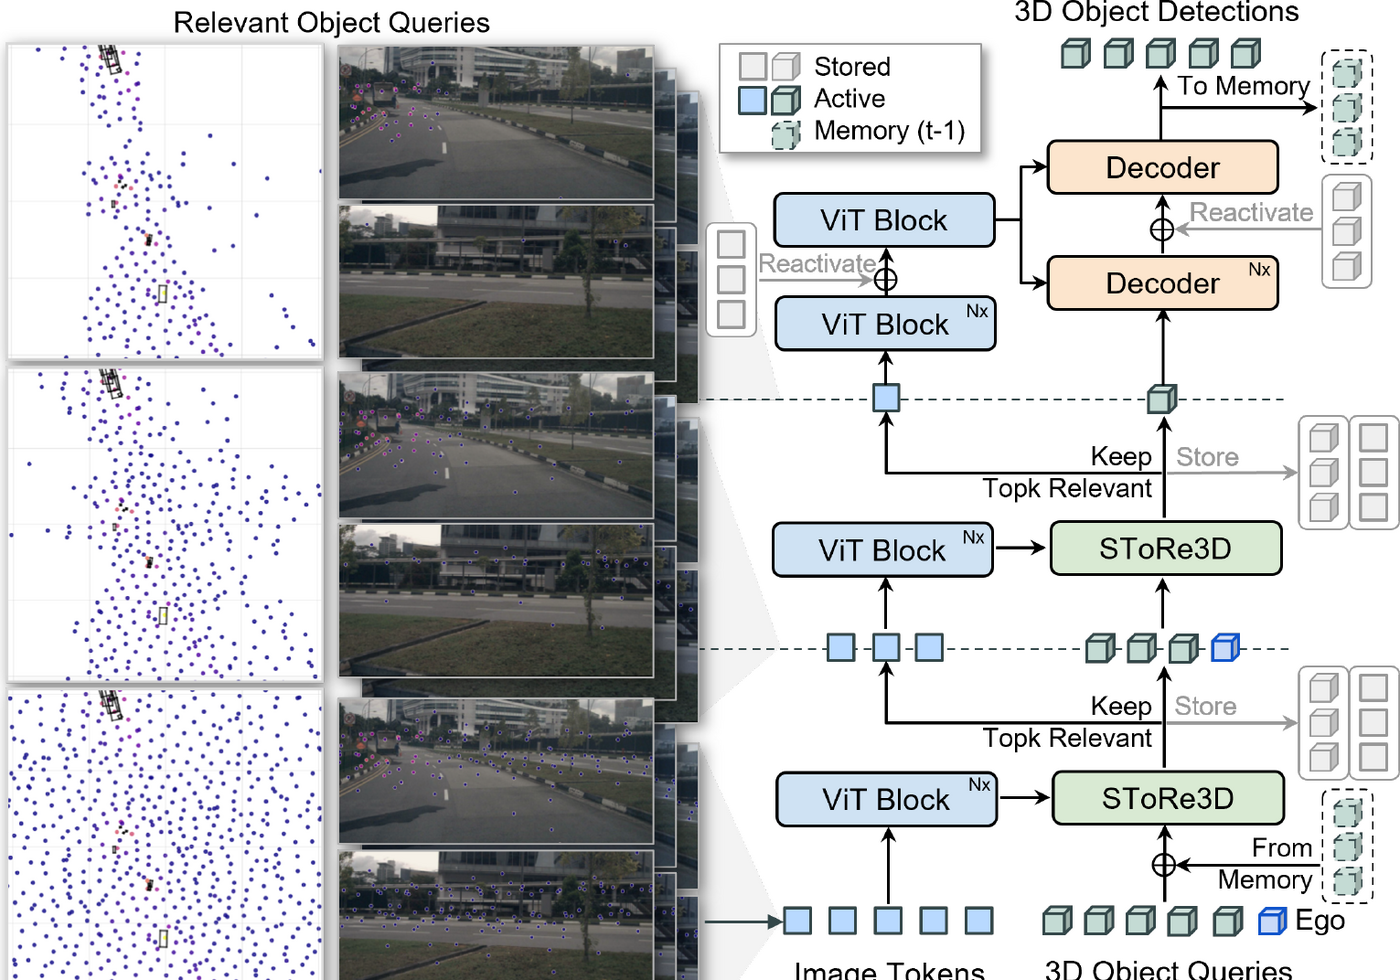 SToRe3D: Sparse Token Relevance in ViTs for Efficient Multi-View 3D Object DetectionIn Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026
-
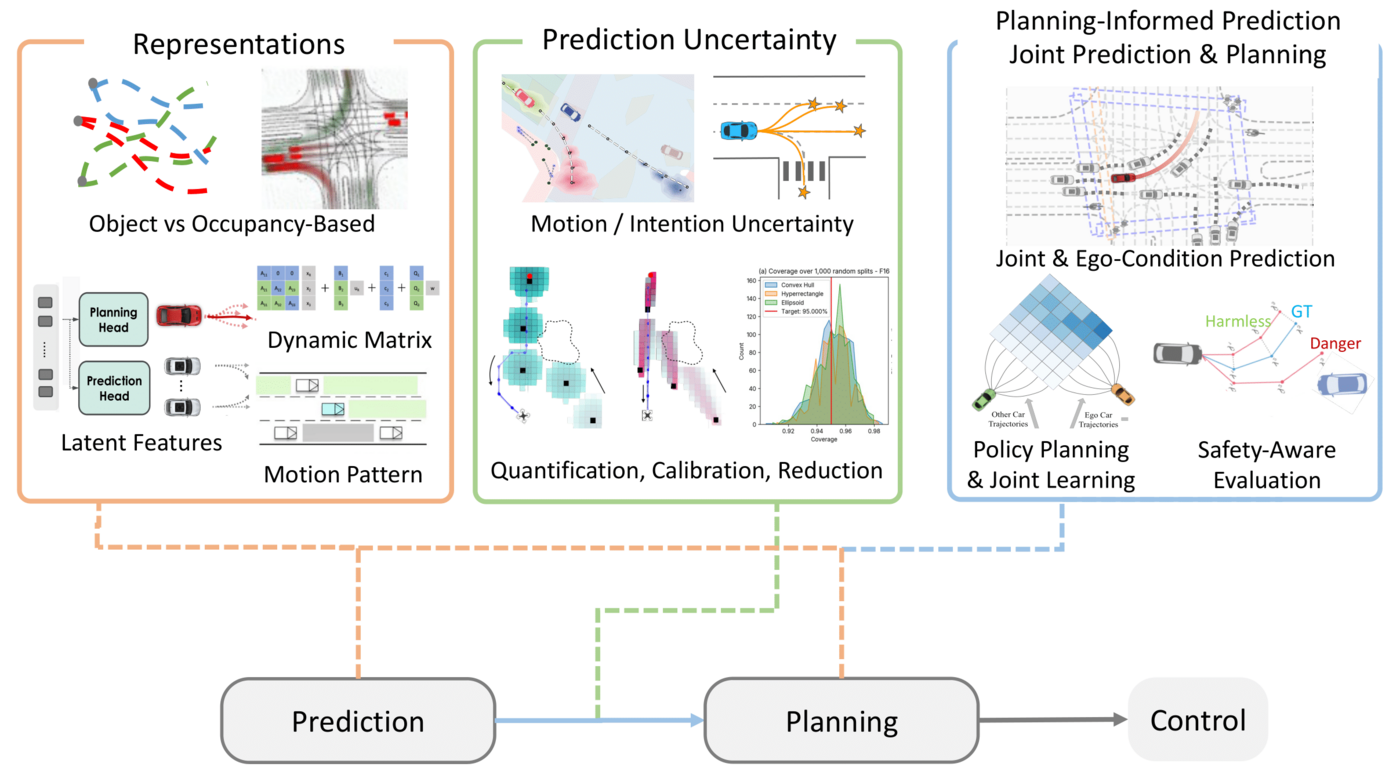 Trends in Motion Prediction Toward Deployable and Generalizable AutonomyFoundations and Trends in Robotics, 2026
-
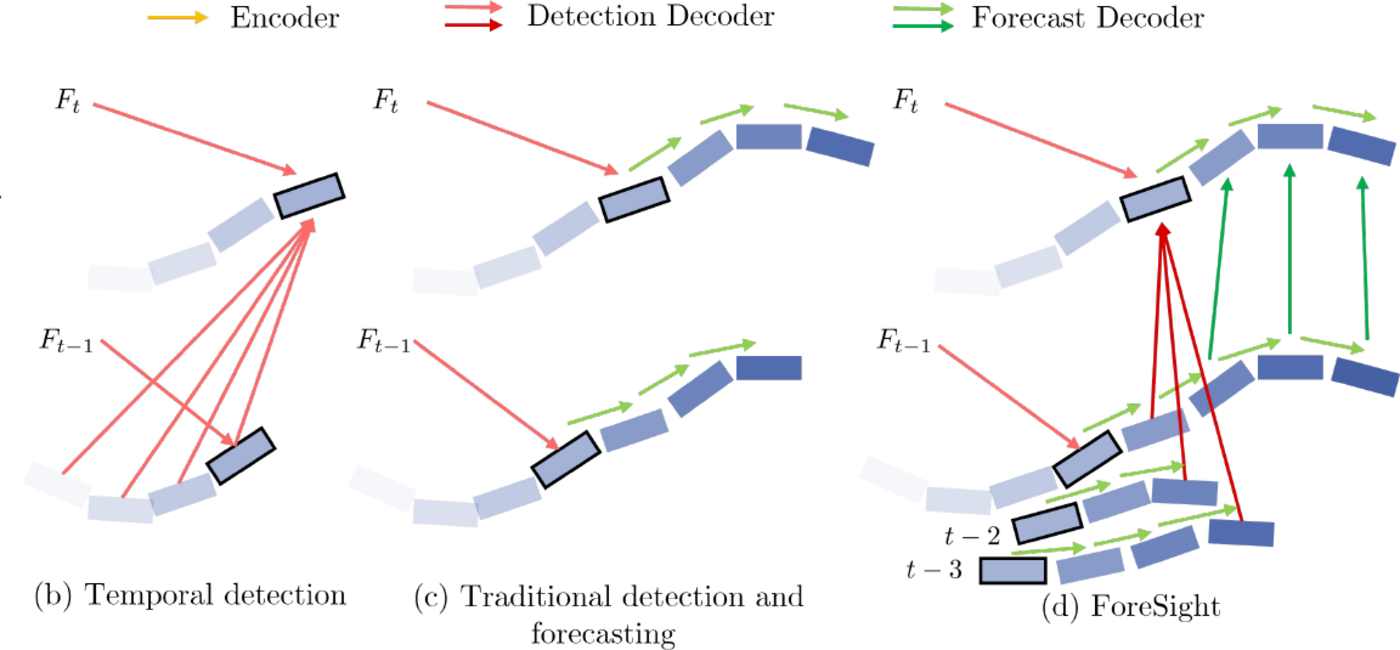 ForeSight: Multi-View Streaming Joint Object Detection and Trajectory ForecastingIn Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), Oct 2025
-
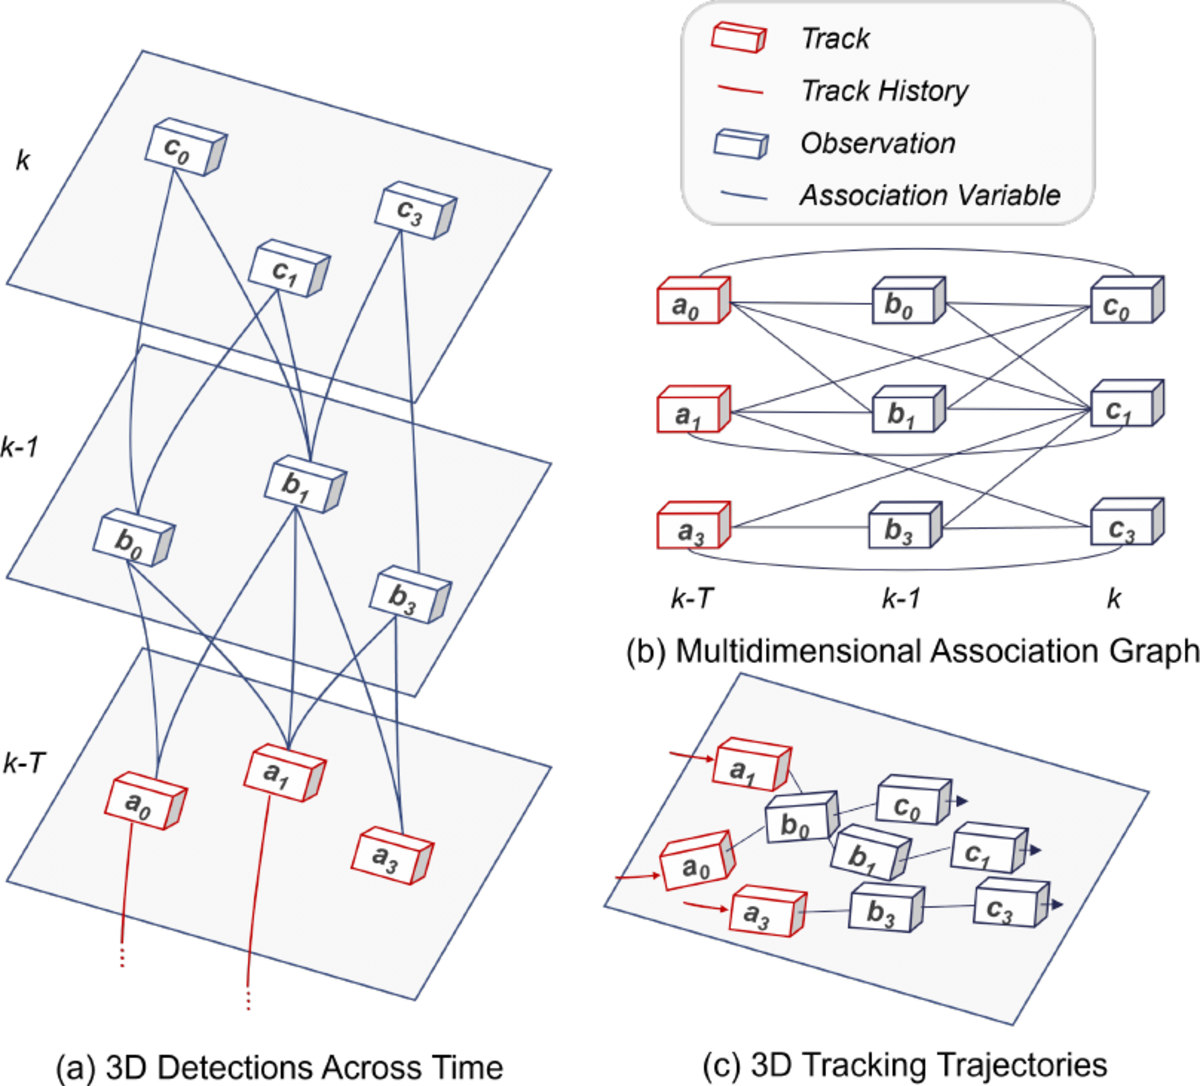 SWTrack: Multiple Hypothesis Sliding Window 3D Multi-Object TrackingIn 2024 IEEE International Conference on Robotics and Automation (ICRA), Oct 2024


Selected Work